Home › Creative Ideas › Robot Dog Joint: Gearbox and Bearings Pulled Apart
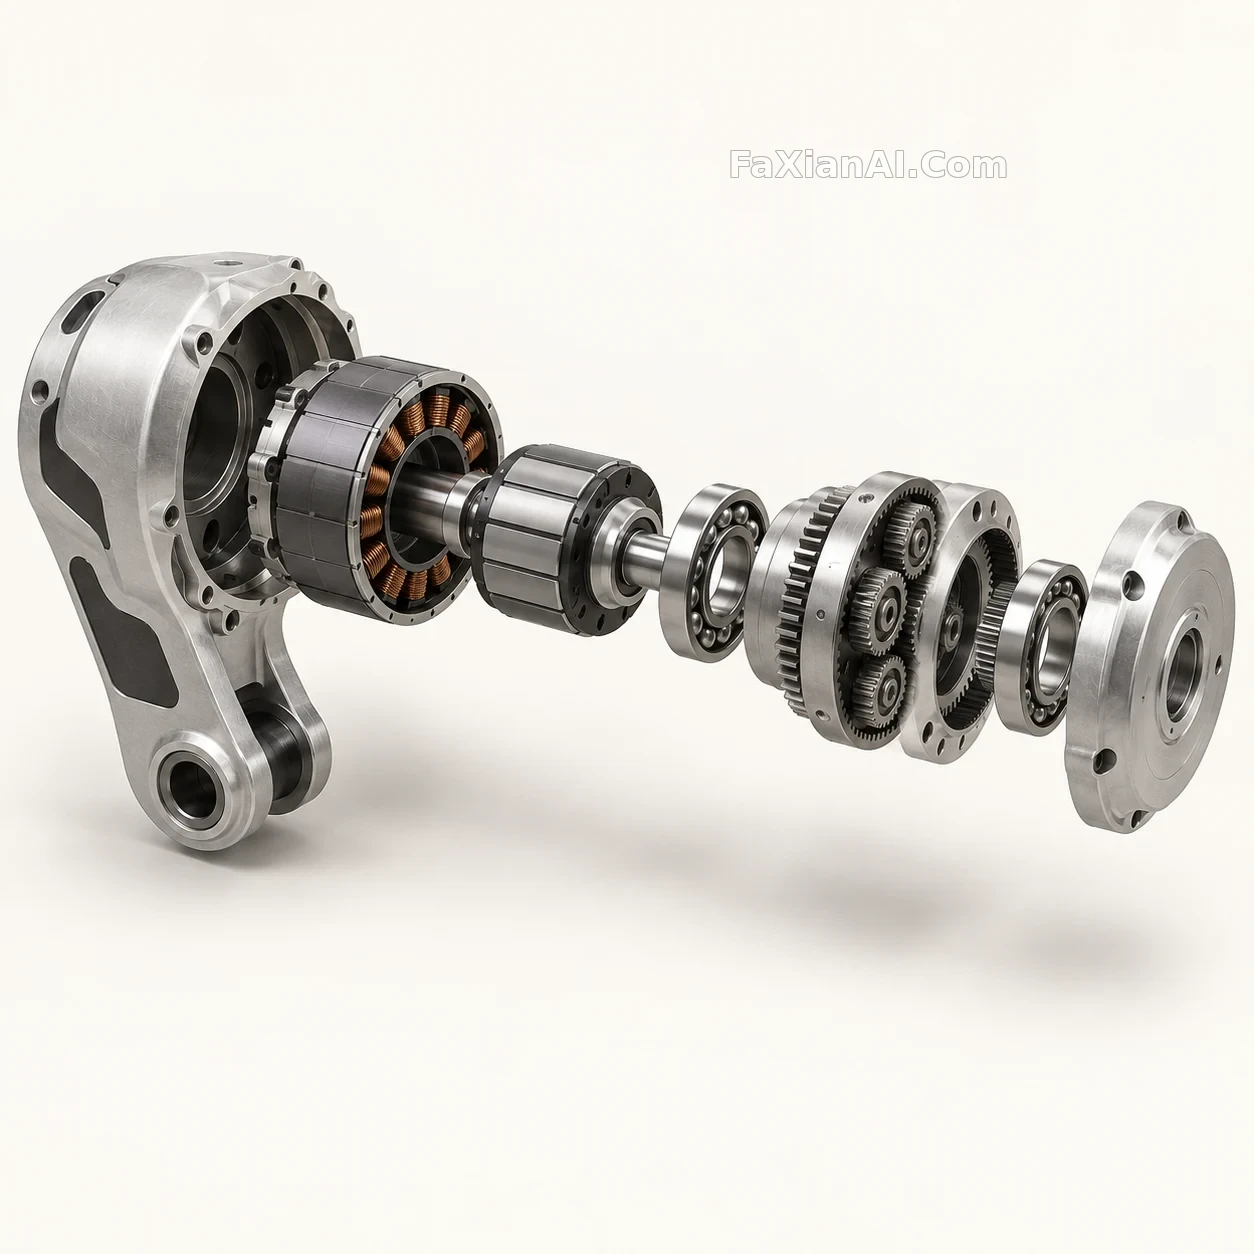
Robot Dog Joint: Gearbox and Bearings Pulled Apart
A 3D concept exploded view of a single robot-dog hip joint module: aluminum housing, motor stator and rotor, reduction gear stage, and bearing rings pulled apart along one horizontal shaft axis.
✍️ The part axis and nesting order are the visual focus — don't imply a real gear ratio. An original concept visualization, not a specific production model or buildable engineering drawing.
📋 Prompt Natural Language
A single robotic dog hip joint module in a precise-looking exploded 3D concept diagram, outer aluminum casing, motor stator and rotor, reduction gear stage and bearing rings separated along one horizontal shaft axis. Ivory background, graphite and brushed metal palette, fine contact shadows, coherent nesting sizes, no text or dimensions, not a build-ready technical drawing. Original generic design, no real brand or fabricated specifications.
Related Cases
 Four Cities Turned Into Rotating Kinetic Sculptures
 Two Figures Give a Courtyard Reading Pavilion Its Scale
 One Warm Trail of Light Follows the Blue-Hour Cycling Track
 Bird's-Eye Wedding Shot, Hooves Fanned at 60°
 A Trader Breaks Down Before the Limit-Down Wall
 Miniature Sushi Chefs Assemble a Dragon Roll